GUTSCHEIN
Bitte haben Sie einen Moment Geduld, wir legen Ihr Produkt in den Warenkorb.
Diese Produkte könnten Sie auch interessieren:
Bitte haben Sie einen Moment Geduld, wir legen Ihr Produkt in den Warenkorb.
| Reihe | Elsevier |
|---|---|
| ISBN | 9780124170490 |
| Sprache | Englisch |
| Erscheinungsdatum | 01.10.2013 |
| Größe | 236 x 161 mm |
| Verlag | Elsevier Inc |
| Lieferzeit | Lieferung in 7-14 Werktagen |
| Herstellerangaben | Anzeigen Libri GmbH Europaallee 1 | D-36244 Bad Hersfeld gpsr@libri.de |
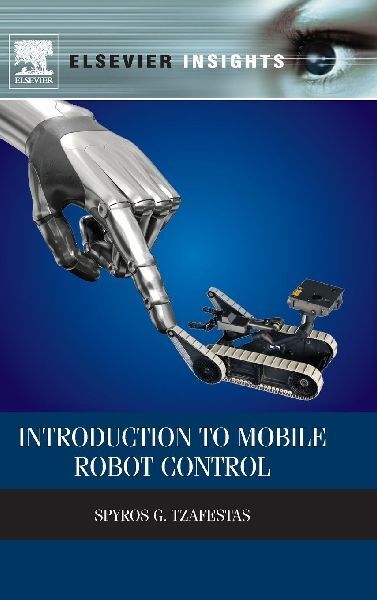
Introduction to Mobile Robot Control provides a complete and concise study of modeling, control, and navigation methods for wheeled non-holonomic and omnidirectional mobile robots and manipulators. The book begins with a study of mobile robot drives and corresponding kinematic and dynamic models, and discusses the sensors used in mobile robotics. It then examines a variety of model-based, model-free, and vision-based controllers with unified proof of their stabilization and tracking performance, also addressing the problems of path, motion, and task planning, along with localization and mapping topics. The book provides a host of experimental results, a conceptual overview of systemic and software mobile robot control architectures, and a tour of the use of wheeled mobile robots and manipulators in industry and society. Introduction to Mobile Robot Control is an essential reference, and is also a textbook suitable as a supplement for many university robotics courses. It is accessible to all and can be used as a reference for professionals and researchers in the mobile robotics field.
| Reihe | Elsevier |
|---|---|
| ISBN | 9780124170490 |
| Sprache | Englisch |
| Erscheinungsdatum | 01.10.2013 |
| Größe | 236 x 161 mm |
| Verlag | Elsevier Inc |
| Lieferzeit | Lieferung in 7-14 Werktagen |
| Herstellerangaben | Anzeigen Libri GmbH Europaallee 1 | D-36244 Bad Hersfeld gpsr@libri.de |
Wie gefällt Ihnen unser Shop?