GUTSCHEIN
Bitte haben Sie einen Moment Geduld, wir legen Ihr Produkt in den Warenkorb.
Diese Produkte könnten Sie auch interessieren:
Bitte haben Sie einen Moment Geduld, wir legen Ihr Produkt in den Warenkorb.
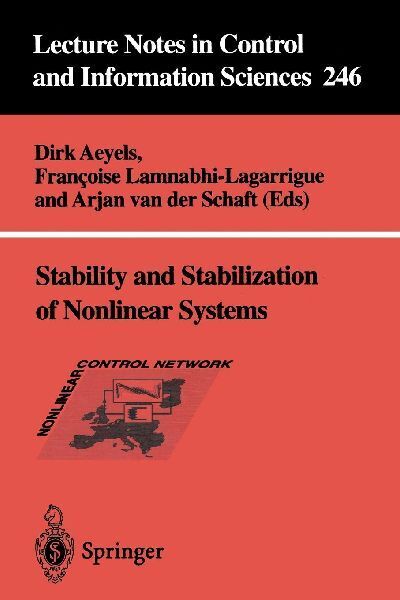
| Reihe | Lecture Notes in Control and Information Sciences |
|---|---|
| Themen | Informatik und Informationstechnologie Informatik Künstliche Intelligenz (KI) |
| ISBN | 9781852336387 |
| Sprache | Englisch |
| Erscheinungsdatum | 18.08.1999 |
| Größe | 235 x 155 mm |
| Verlag | Springer |
| Herausgegeben von | Dirk Aeyels, Arjan Van Der Schaft, Francoise Lamnabhi-Lagarrigue |
| Lieferzeit | Lieferung in 7-14 Werktagen |
| Herstellerangaben | Anzeigen Europaplatz 3 | DE-69115 Heidelberg ProductSafety@springernature.com |
Disturbance attenuation for discrete-time feedforward nonlinear systems.- Further results on decoupling with stability for Hamiltonian systems.- Issues in modelling and control of mass balance systems.- Control of dynamic bifurcations.- Extension of Popov criterion to time-varying nonlinearities: LMI, frequential and graphical conditions.- Uniqueness of control sets for perturbations of linear systems.- Design of control Lyapunov functions for "Jurdjevic-Quinn" systems.- Bifurcation analysis of a power factor precompensator.- Stabilization by sampled and discrete feedback with positive sampling rate.- Linear controllers for tracking chained-form systems.- Asymptotic methods in stability analysis and control.- Robust point-stabilization of nonlinear affine control systems.- Stabilization of port-controlled Hamiltonian systems via energy balancing.- Invariant tracking and stabilization: problem formulation and examples.- Control of mechanical structures by piezoelectric actuators and sensors.- A novel impedance grasping strategy as a generalized hamiltonian system.- A nonsmooth hybrid maximum principle.- A converse Lyapunov theorem for robust exponential stochastic stability.- LMIs for robust stable neural model-based control.
| Reihe | Lecture Notes in Control and Information Sciences |
|---|---|
| Themen | Informatik und Informationstechnologie Informatik Künstliche Intelligenz (KI) |
| ISBN | 9781852336387 |
| Sprache | Englisch |
| Erscheinungsdatum | 18.08.1999 |
| Größe | 235 x 155 mm |
| Verlag | Springer |
| Herausgegeben von | Dirk Aeyels, Arjan Van Der Schaft, Francoise Lamnabhi-Lagarrigue |
| Lieferzeit | Lieferung in 7-14 Werktagen |
| Herstellerangaben | Anzeigen Europaplatz 3 | DE-69115 Heidelberg ProductSafety@springernature.com |
Wie gefällt Ihnen unser Shop?
