GUTSCHEIN
Bitte haben Sie einen Moment Geduld, wir legen Ihr Produkt in den Warenkorb.
Diese Produkte könnten Sie auch interessieren:
Bitte haben Sie einen Moment Geduld, wir legen Ihr Produkt in den Warenkorb.
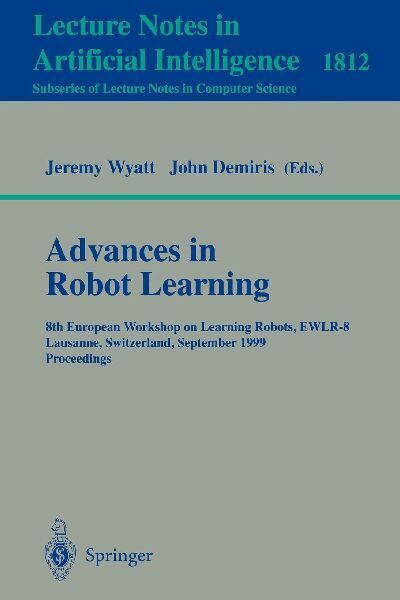
| Reihe | Lecture Notes in Computer Science |
|---|---|
| Themen | Informatik und Informationstechnologie Informatik Künstliche Intelligenz (KI) |
| ISBN | 9783540411628 |
| Sprache | Englisch |
| Erscheinungsdatum | 11.10.2000 |
| Größe | 235 x 155 mm |
| Verlag | Springer |
| Herausgegeben von | Jeremy Wyatt, John Demiris |
| Lieferzeit | Lieferung in 7-14 Werktagen |
| Herstellerangaben | Anzeigen Europaplatz 3 | DE-69115 Heidelberg ProductSafety@springernature.com |
Map Building through Self-Organisation for Robot Navigation.- Learning a Navigation Task in Changing Environments by Multi-task Reinforcement Learning.- Toward Seamless Transfer from Simulated to Real Worlds: A Dynamically-Rearranging Neural Network Approach.- How Does a Robot Find Redundancy by Itself?.- Learning Robot Control by Relational Concept Induction with Iteratively Collected Examples.- Reinforcement Learning in Situated Agents: Theoretical Problems and Practical Solutions.- A Planning Map for Mobile Robots: Speed Control and Paths Finding in a Changing Environment.- Probabilistic and Count Methods in Map Building for Autonomous Mobile Robots.- Biologically-Inspired Visual Landmark Learning for Mobile Robots.
| Reihe | Lecture Notes in Computer Science |
|---|---|
| Themen | Informatik und Informationstechnologie Informatik Künstliche Intelligenz (KI) |
| ISBN | 9783540411628 |
| Sprache | Englisch |
| Erscheinungsdatum | 11.10.2000 |
| Größe | 235 x 155 mm |
| Verlag | Springer |
| Herausgegeben von | Jeremy Wyatt, John Demiris |
| Lieferzeit | Lieferung in 7-14 Werktagen |
| Herstellerangaben | Anzeigen Europaplatz 3 | DE-69115 Heidelberg ProductSafety@springernature.com |
Wie gefällt Ihnen unser Shop?
